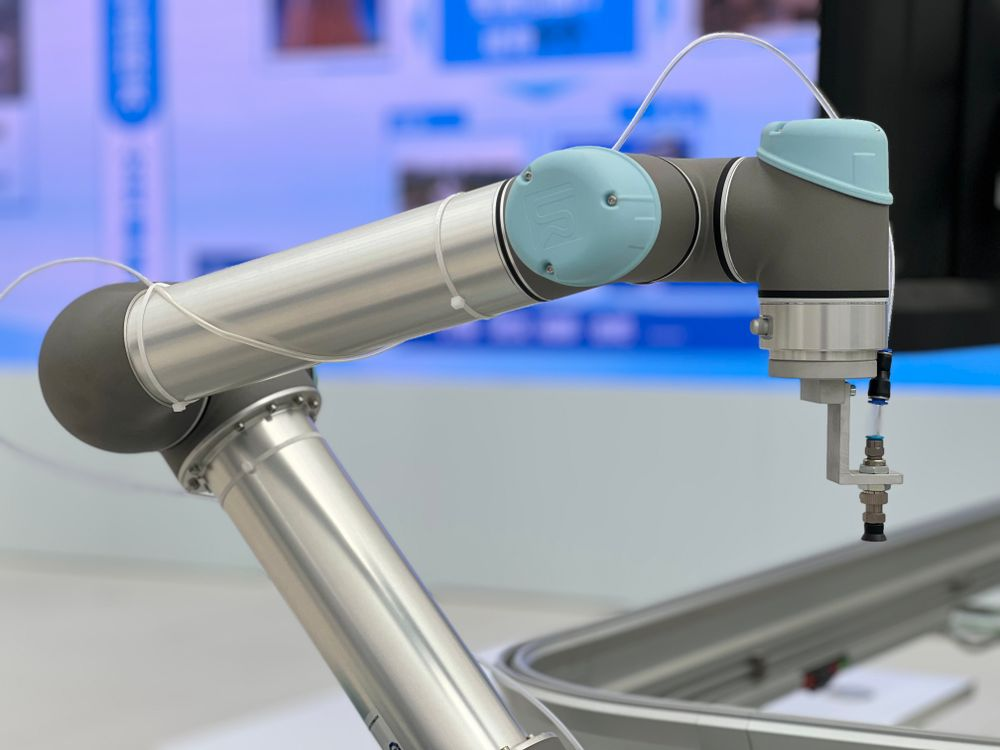
KUKA announced iiQKA.AI Vision on 8 October 2026, introducing image-processing software integrated into its robotics ecosystem. The offering supports two-dimensional and three-dimensional vision tasks including bin picking, assembly, quality inspection and depalletising. The release concerns a new software capability rather than a completed installation at a named factory.
The company describes drag-and-drop configuration intended to reduce the specialist expertise previously required for many vision applications. Integration may simplify deployment for users already operating compatible KUKA equipment, although actual configuration work and commissioning time depend on the application and workcell design.
Industrial vision is used to locate objects, inspect features and guide robot movement. Images must be interpreted in the context of lighting, surface properties, geometry and acceptable positional error. A demonstration under controlled conditions does not automatically show that a system can handle every variability found in production.
KUKA describes its iiQKA.AI Vision capability as an integrated 2D and 3D vision approach for industrial robot applications. The announcement sets out a product capability and intended tasks, not a measured improvement across every factory configuration. Claims about defect detection, accuracy or labour savings must be tied to particular applications and validation conditions rather than assumed from the launch.
KUKA describes iiQKA.AI Vision as integrated robot vision software with 2D and 3D functions. The original announcement does not supply independently verified defect-detection accuracy for every use case. Performance would have to be validated for each application, including the object, lighting conditions and acceptance tolerances.
The integrated architecture is relevant because a conventional robot-vision project can involve separate cameras, processors, configuration applications and communications links. Reducing the number of interfaces may make maintenance simpler, but users should verify the supported hardware and software versions.
KUKA says the tool is aimed partly at integrators and operators with limited specialist experience. That ambition should not be confused with eliminating the need for a risk assessment. Any new robot application still requires appropriate guarding, safe operating procedures and validation of movements.
Operators will also need to consider how models or image-processing rules are maintained. Changes to a part, package or lighting layout can affect interpretation. A robust process should allow engineers to test a revised configuration and determine whether it changes quality or handling performance.
Depalletising and assembly demonstrate the different purposes of machine vision. One requires reliable location of packages in a changing stack, while the other can demand accurate alignment of components. The same interface may support both, but the accuracy and cycle-time requirements should be established for each job.
An integrated software interface may also reduce reliance on multiple specialist programming environments. Nonetheless, the practical measure is the time from installation to repeatable production, not the number of clicks involved in initial demonstration. Manufacturers should seek evidence from representative materials and line speeds.
The company has not provided a universal quantified improvement in throughput or labour requirement that could be applied across all robot cells. Such outcomes depend on upstream feeding, gripper suitability and downstream equipment. The 8 October announcement establishes the launch and its intended application scope.
Customer production references could demonstrate production references showing commissioning effort, uptime, repeatable positional accuracy and maintenance needs. Those measures would help determine where iiQKA.AI Vision changes the economics of deploying machine vision rather than merely simplifying the user interface.
Machine vision must operate within the broader sequence of production. A robot may identify a part correctly yet be unable to place it at the required speed because of gripper travel or an obstruction. Integrators need to test these interactions under the expected range of materials and operating conditions.
The system’s claimed simplicity will be most meaningful for plants that need to reconfigure tasks frequently. Those users should assess not only first-time programming but also how technicians modify a cell safely after tooling changes. A clear interface can support this work, but cannot replace formal change management.
Image-based handling can also be affected by reflections, transparent packaging, dust and occlusion. These challenges differ between industries. The vendor’s ability to support both 2D and 3D applications does not remove the need to choose suitable sensing methods for each physical task.
Commissioning evidence should distinguish a successful demonstration from sustained production. Overall equipment effectiveness, reject rates and maintenance interventions provide a more robust picture than an isolated cycle-time claim. They will also show whether an integrated system can be supported by an ordinary factory engineering team.